
ALSONTECH 3D Vision Bin Picking Solution
About Bin Picking
"Bin picking", one of the most common incoming forms on the production site, is also the most difficult form in the automation industry. When we deal with Bin pickinged workpieces where the whole frame looks random,scattered, and stacked, we cannot set a fixed grasping order through robot programming, and we also need to face possible interference and collision between the robot, the workpiece, and the material frame, as well as the robotovertraveling, jamming, etc.
Is there a solution that can predict and solve theabove application pain points, help users achieve chaos and order, and greatly improve the bin cleaning rate?
Introduction to the program
After repeated practice,ALSONTECH provides endusers and integrator partners with 3D vision solutions for Bin picking applications, and uses high quality software and hardware products and supporting services to help the project be implemented.
Simulate a real picking environment
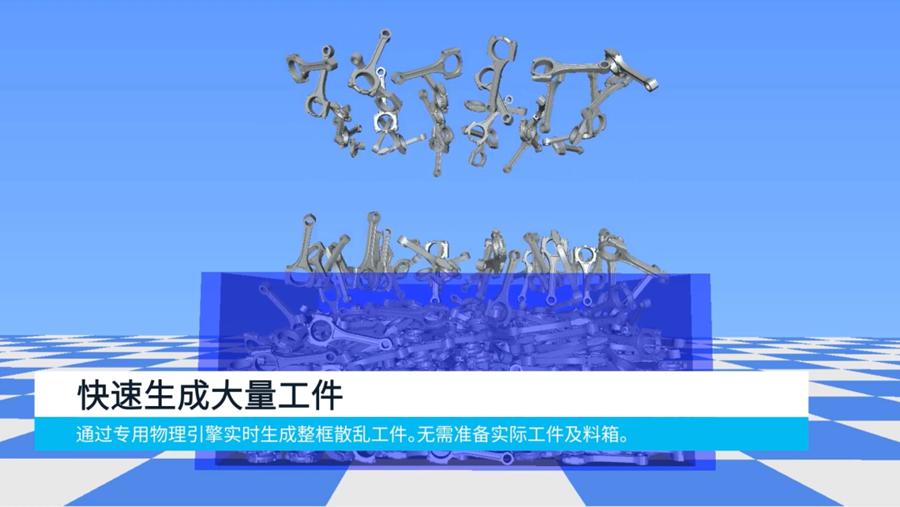
ALSONTECH provides users with a professional offlinesimulation programming operating environment- LightBinPick, in this environment, users can import 3D camera, robot brand/model, workpiece digital model, material frame and other elements through the software, andbuild a real grabbing scene by setting environmental parameters to simulate, inthe early stage of the project, users can quickly evaluate the feasibility ofthe project without spending a lot of manpower and material resource to deploy.
Offline point cloud processing
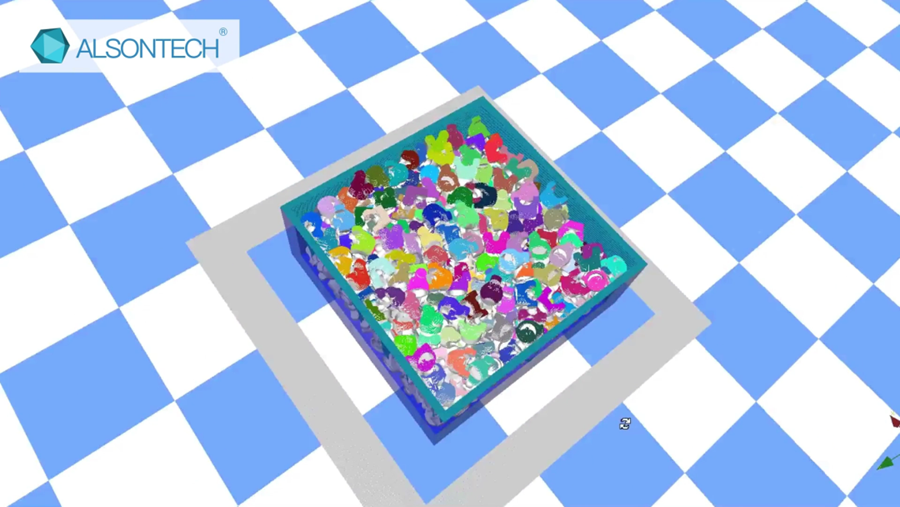
Users can set 3D camera parameters in thesimulation environment, simulate the scanning of the workpiece, and dynamicallygenerate point cloud data in preparation for subsequent capture.
Design a reasonable picking path
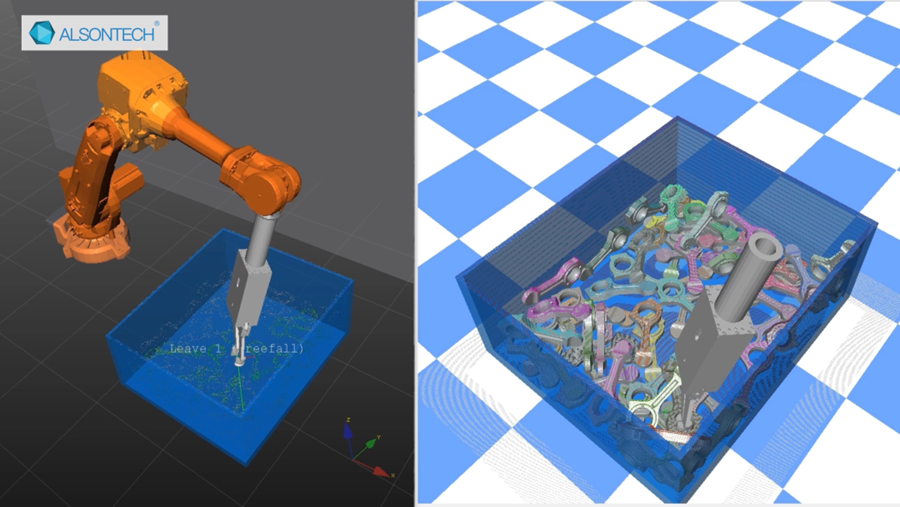
Users can simulate real grasping actions in the simulation environment, find abnormal situations such as interference points ingrasping, visually register multiple grasping positions and corresponding placement postures for workpieces, and automatically plan the grasping path (including grasping trajectories, lifting trajectories, placement trajectories,etc.) to avoid collisions, robot singularities, overtravel and other situations. At the same time, if the design of the fixture and the materialframe is found to be unreasonable in the simulation of grabbing, odification suggestions can also be output to the user according to the data statistics results to avoid material loss after later production.
Deploy multiple picking strategies
The solution uses a variety of recognition and capture strategies such as TCP planning, attitude reset, local difference regional matching, and AI+3D composite matching to further strengthen the recognition success rate and recognition speed, and greatly improve the basket clearing rate. As shown in the figure below, for the situation that the workpiece attitude does not meet the loading requirements or cannot be grasped,the attitude reset strategy can be called to adjust the workpiece posture to facilitate the robot's subsequent grasping and loading in the required attitude.
(Workpiece Direction Reset Strategy)
High beat grabbing to improve bin cleaning rate
Under the premise of ensuring the feasibility and safety of grasping, due to the stacking of workpieces, the posture of the remaining workpieces will change at any time during the picking process, and there are many uncertain factors, and quickly emptying the full-frame workpiece is the final demand of users. After the continuousim provement of the picking algorithm and the continuous improvement of the performance of high-beat 3D cameras, after the accumulation of a large number of on-site delivery experience, the current implementation of the scheme for conventional workpieces can achieve vision efficiency of 3s/piece, basket cleaning rate of up to 99%, to meet the requirements of the vast majority of production sites.
At the same time, the solution can also be extended to the deep frame handling condition of relatively ordered incoming forms, which can help users effectively avoid the risk of collision after the fixture entersthe frame and solve the problem of leftover materials of the attached workpiece. ALSONTECH can provide a large-field 3D camera to achieve one-timeout put of multiple workpiece coordinates by covering the same layer of workpieces with an effective field of view, reducing the time-consuming time caused by repeated scanning and improving the grasping cycle.
Applicationcases
In order to improve the level of automation, acasting enterprise uses robots to feed the castings. The workpiece bin is transported in place by forklift, the workpiece is placed Binpicking in the frame, and manual teaching and ordinary camera recognition cannot complete effective grasping.
Project difficulties
o The incoming state of the workpiece is completely Binpickinged, scattered and laminated
o The size of the material frame is large, and itneeds to be covered by a large field of view visual product
o The depth of the material frame is high, and thefixture completely enters the material frame after grabbing the middle layer, and the risk of collision is large
o Dark workpieces, flat on one side, are prone tostand on the side wall of the bin
o In order to ensure production efficiency, high cycle times are required
o The clearance rate is required to reduce manual intervention
Project implementation
o Using ALSONTECH large field of view 3D cameraAT-S1000-01C-H, the grating scheme has high precision and high cycle characteristics, and the project has been comprehensively evaluated in thesimulation environment in the early stage, and the grabbing strategy is reasonablyset according to the evaluation results to achieve the requirements of the on-site bin clearance rate.


